Joint ESDF for Trajectory Optimization of Arbitrarily Shaped Multi-Robot Systems
Ongoing work.
Planning coordinated motion for multiple robots becomes challenging when their shapes are complex or nonconvex. This project explores trajectory optimization with joint Euclidean signed distance fields (ESDFs), aiming to account for robot geometry while avoiding collisions with obstacles and other robots. We focus on finding feasible motions through shared spaces, where both the paths robots take and the timing of their movements matter.
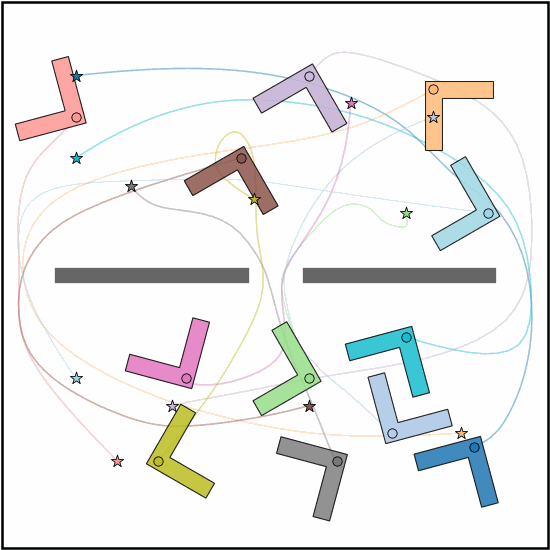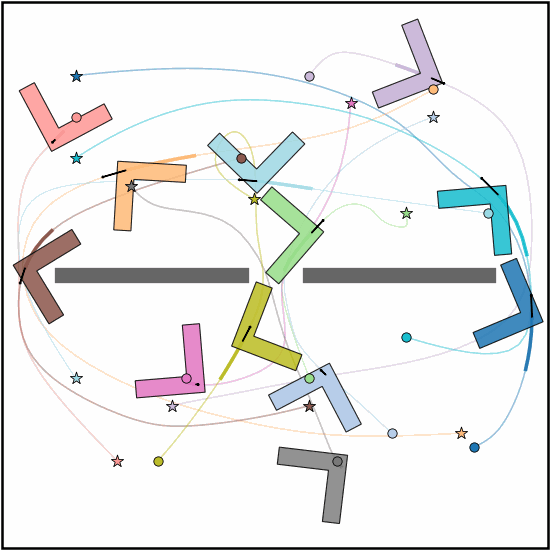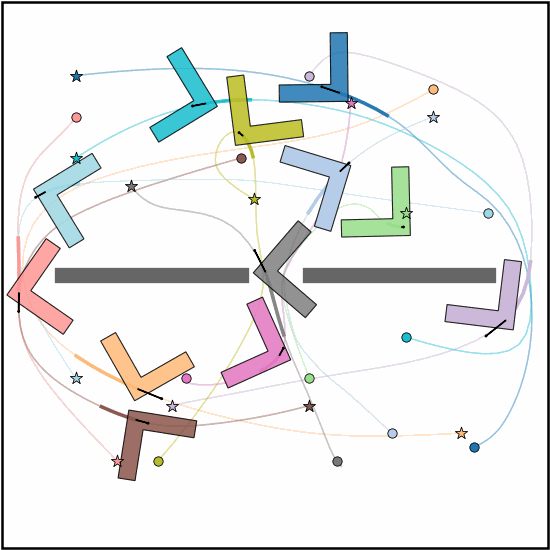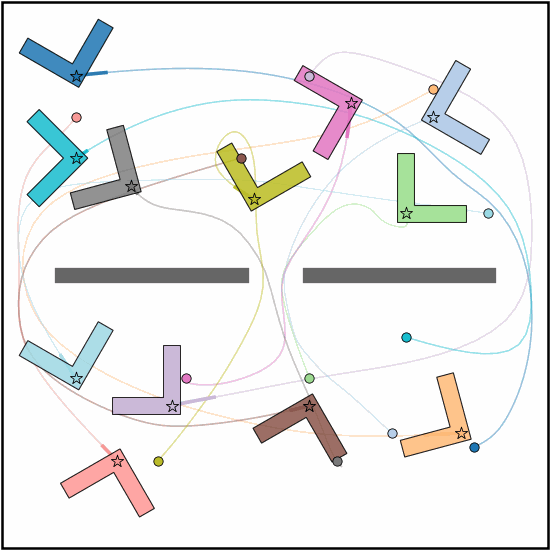
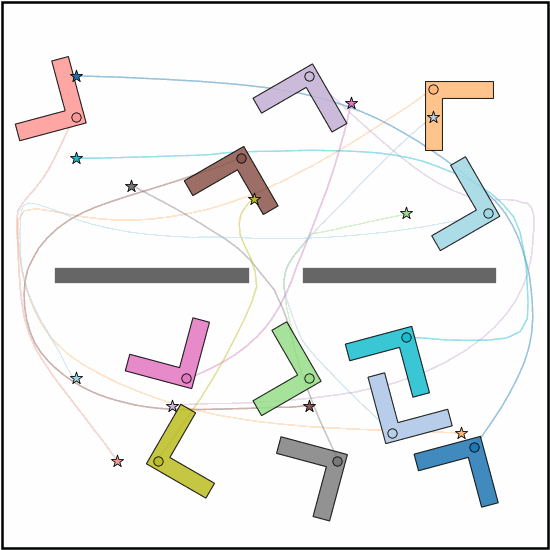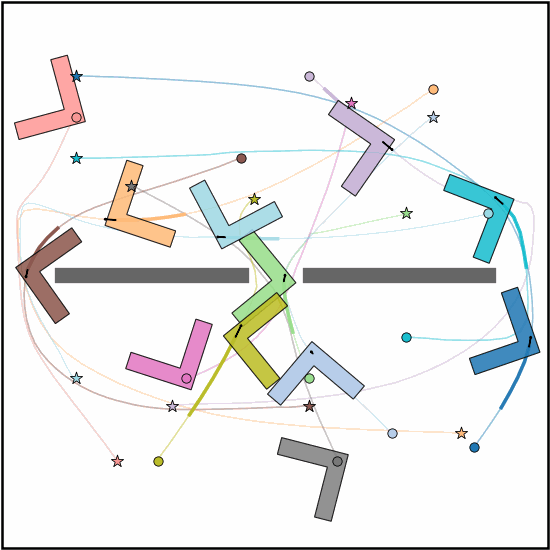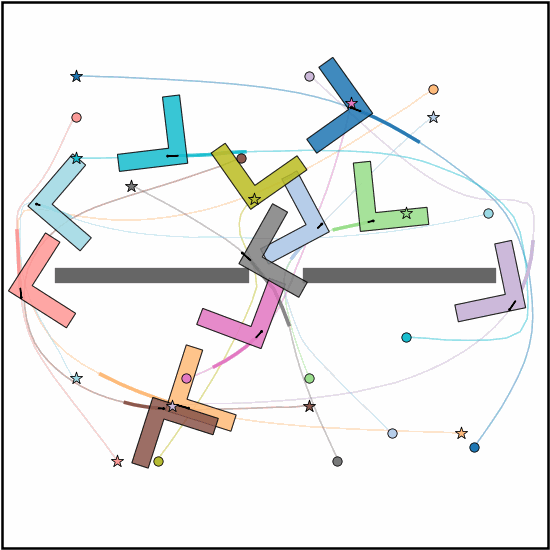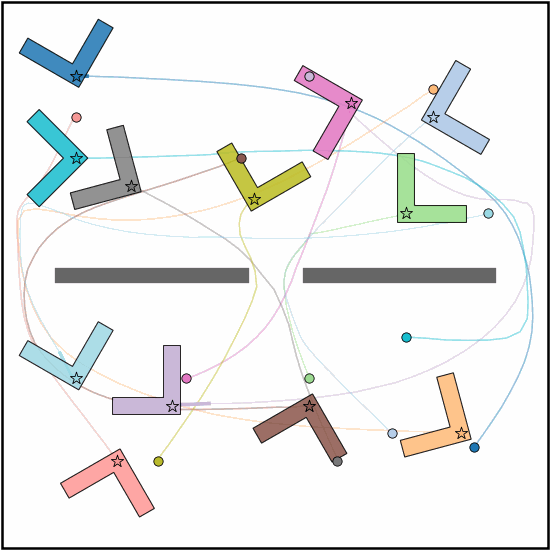
The following animations illustrate preliminary examples from this ongoing work.